Hi, I am Jingze Wu. I graduated from Sun Yat-sen University with a Master’s degree in Electronic and Information Engineering, supervised by Professor Hongbo Chen. Now, I am a Research Assistant at Centre for Artificial Intelligence and Robotics, Hong Kong Institute of Science & Innovation, Chinese Academy of Sciences, supervised by Assistant Professor Fei Zhu.
💡 Research Interests
My research seeks to build robust and generalizable multimodal intelligence, which will give robots truly smart brains that can perceive, reason, and interact with the physical world seamlessly. By bridging generation and understanding, I aim to enable AI systems to learn from limited data, continuously evolve through interaction, and generalize across diverse real-world scenarios. Specifically, I focus on:
- Efficient Fine-Tuning: Introducing causal priors and physical laws to maximize model training results and learning generalization with limited data
- Agent Harness: Self-evolving agents
- Embodied AI: Unified generation-understanding model for robot
Do not hesitate to drop me an email for any possible idea if you are interested in these directions!
🔥 News
∙ 2026/06: One paper is accepted by ECCV 2026.
∙ 2026/02: Two papers are accepted by CVPR 2026.
∙ 2025/11: One paper is accepted by AAAI 2026.
∙ 2025/04: One paper is accepted by IJCAI 2025.
👨🎓 Education
-
M.Eng. in Electronic and Information Engineering, Sun Yat-sen University
Supervisor: Professor Hongbo ChenThesis: Causality-Enhanced Multimodal Large Language Model for Video Understanding
-
B.Sc. in Applied Statistics, Northeastern University
Thesis: Research on The Random Error Modeling for Gyro
💻 Work Experience
- Research Assistant, Centre for Artificial Intelligence and Robotics, Hong Kong Institute of Science & Innovation, Chinese Academy of Sciences
📝 Publications
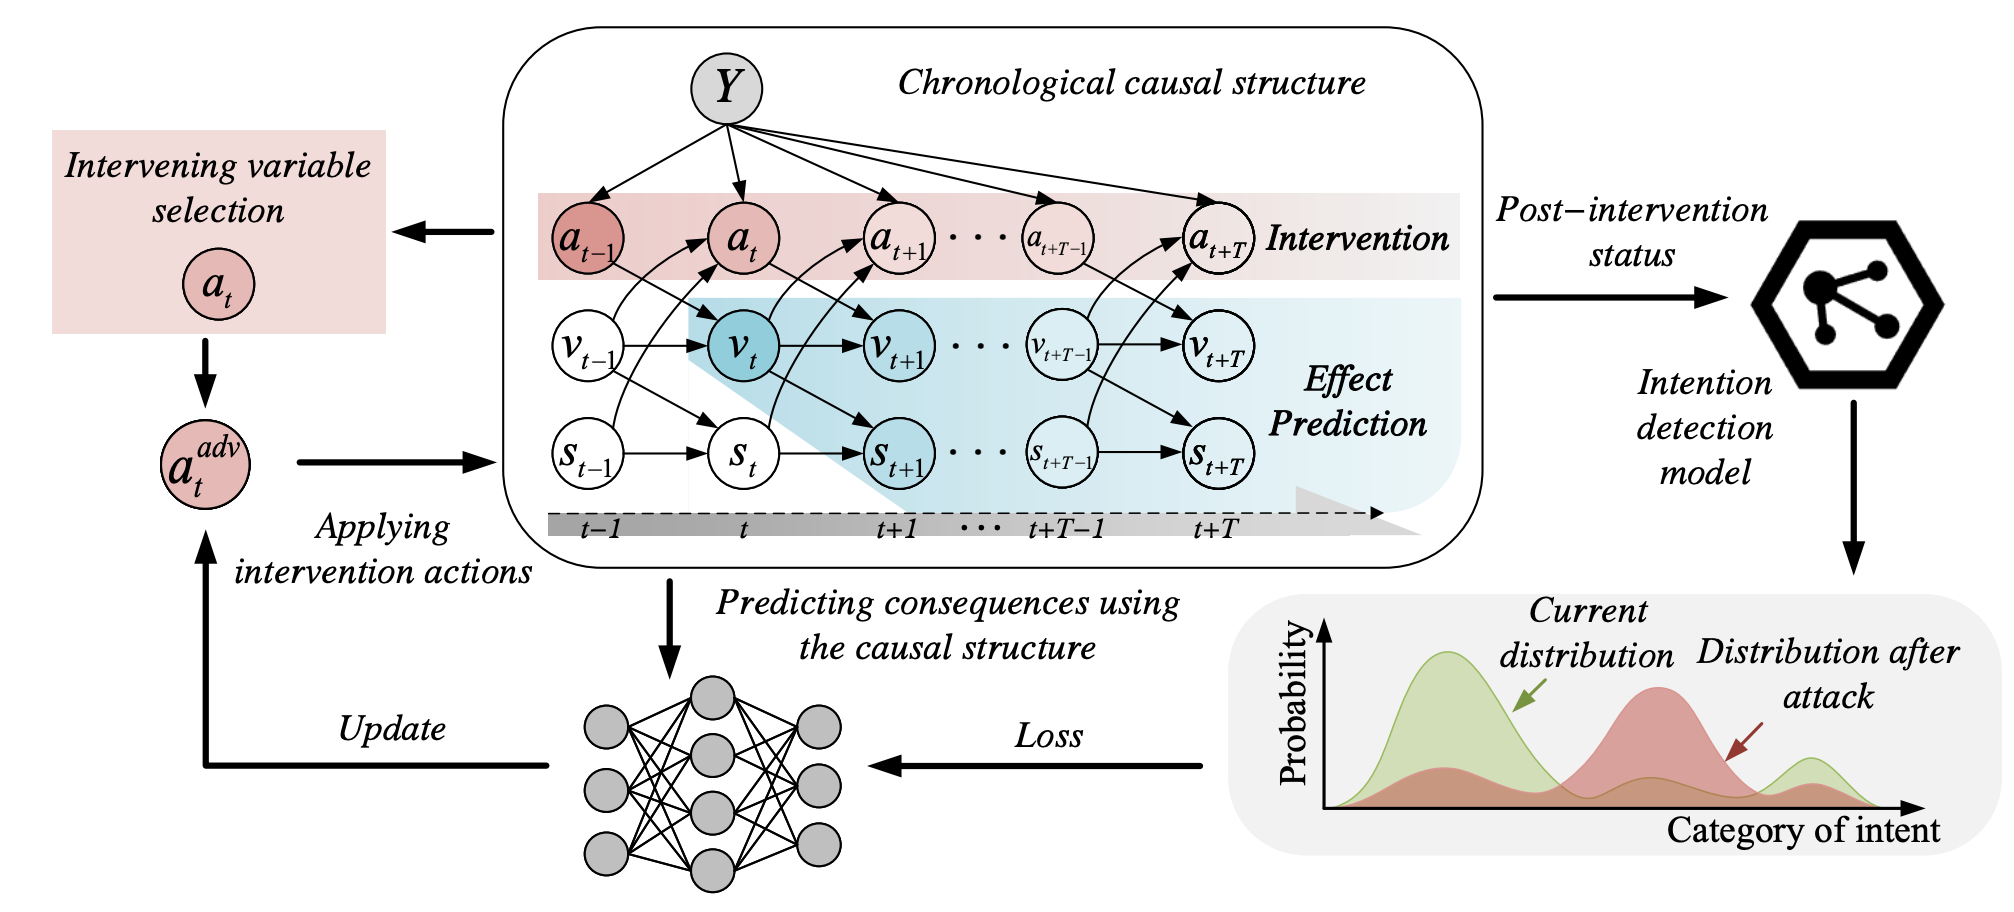
Causality-inspired kinematics-constrained adversarial trajectory generation for swarm intention recognition
Guanjun Wang, Jingze Wu, Hongbo Chen$^{\ast}$
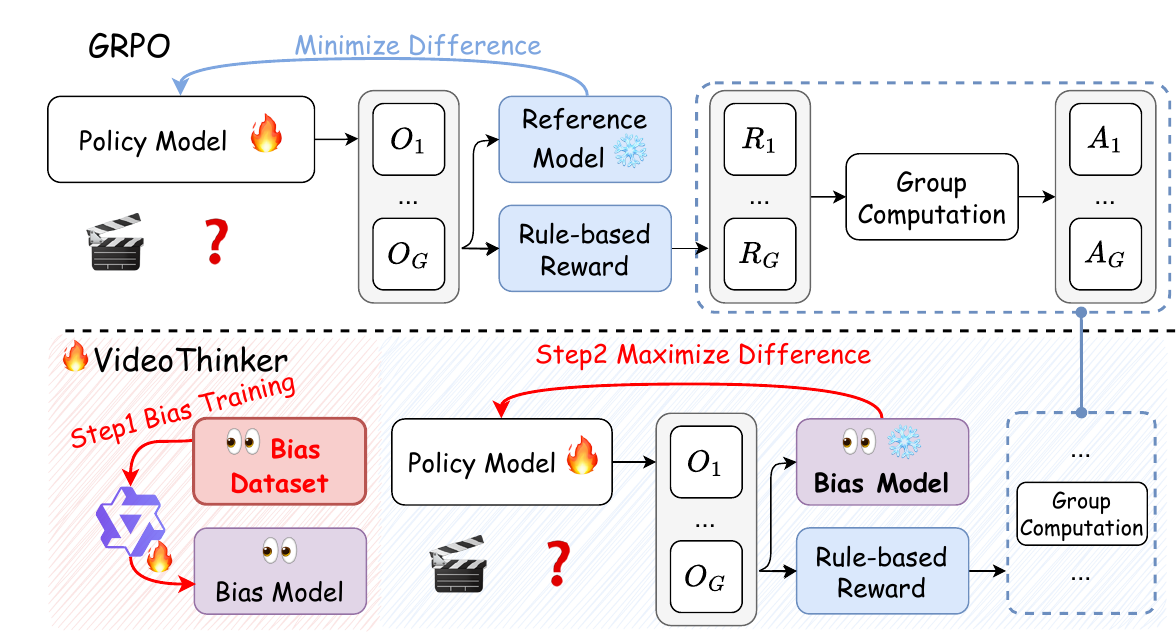
Beyond Perceptual Shortcuts: Causal-Inspired Debiasing Optimization for Generalizable Video Reasoning in Lightweight MLLMs
Jingze Wu, Quan Zhang$^{\ast}$, Hongfei Suo, Zeqiang Cai, Hongbo Chen$^{\ast}$
The IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2026
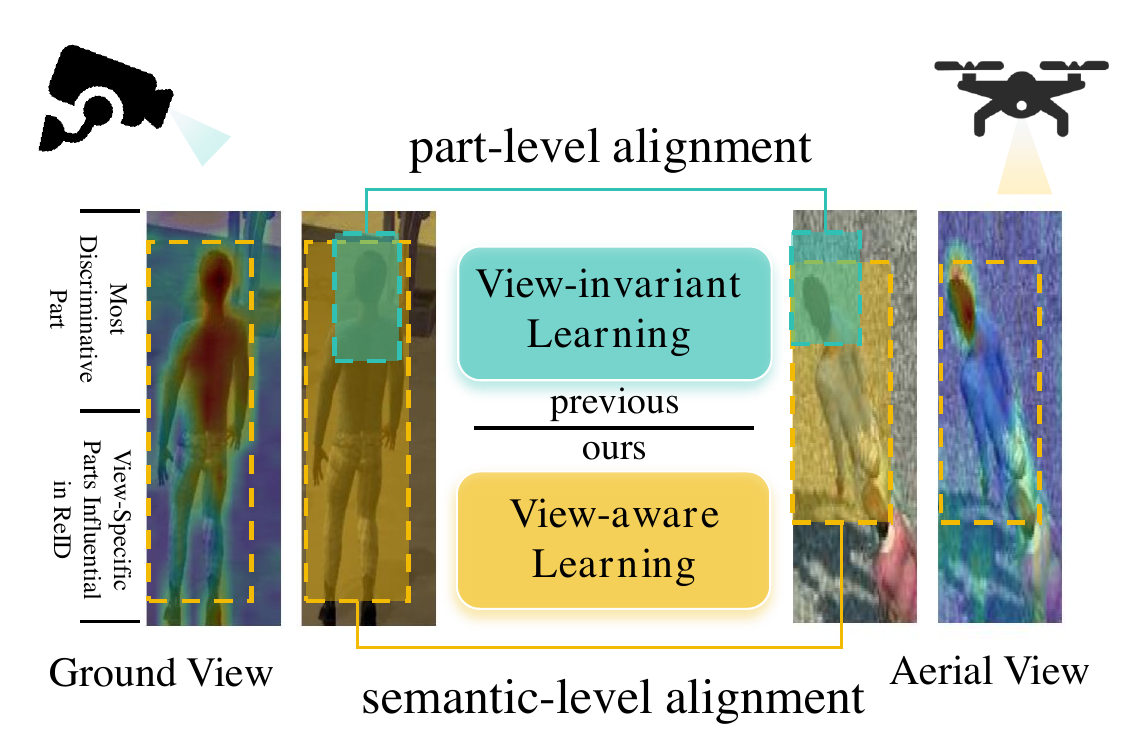
View-Aware Semantic Alignment for Aerial-Ground Person Re-Identification
Quan Zhang$\dagger$, Zeqiang Cai$\dagger$, Peiming Zhao, Jingze Wu, Cailun Wu, Hongbo Chen, Jianhuang Lai$^{\ast}$
The IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2026
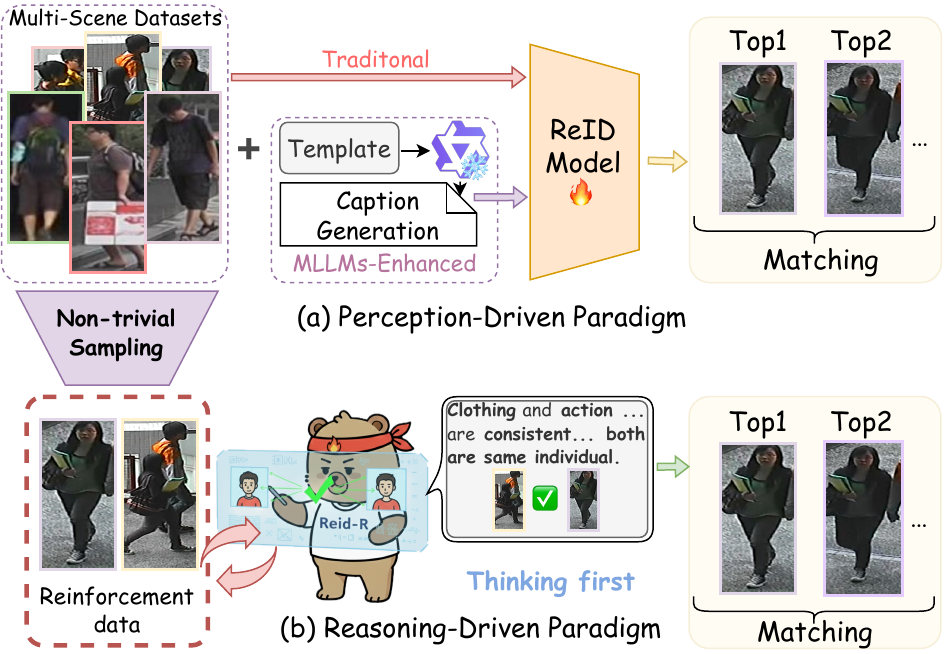
Thinking Before Matching: A Reinforcement Reasoning Paradigm Towards General Person Re-Identification
Quan Zhang$\dagger$, Jingze Wu$\dagger$ (Student first author), Jialong Wang, Xiaohua Xie, Jianhuang Lai$^{\ast}$, Hongbo Chen$^{\ast}$
arXiv preprint arXiv:2604.19218, 2026
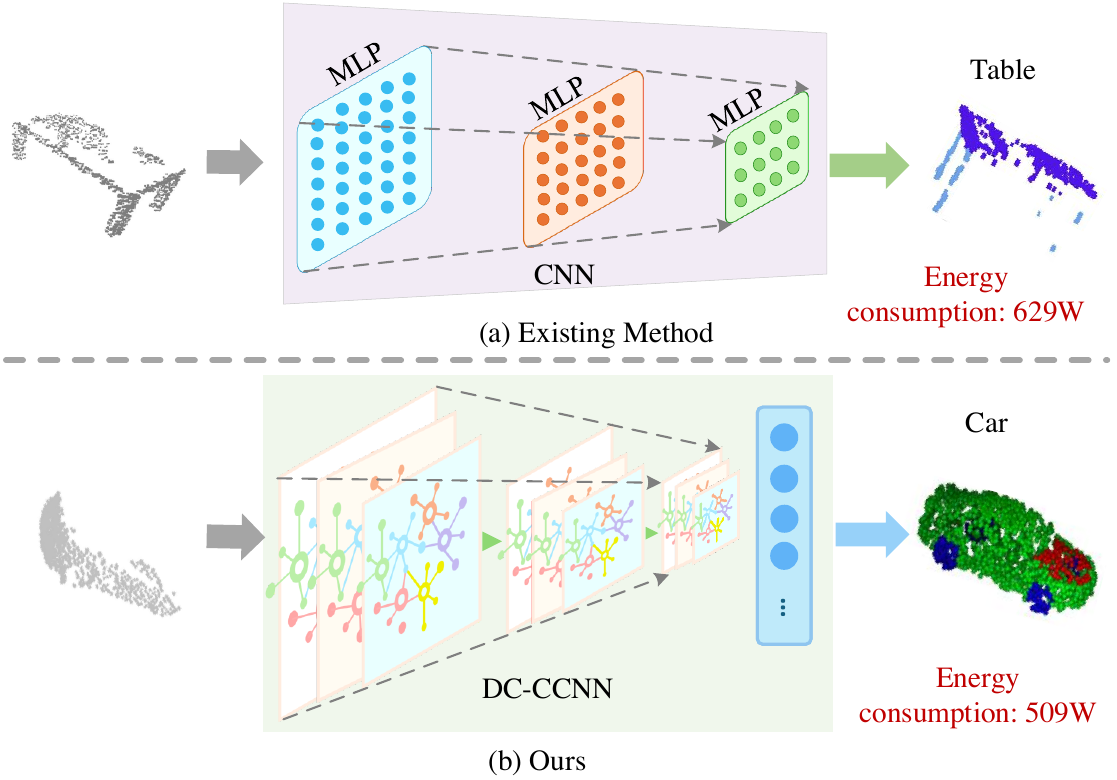
Primary visual cortex inspired point cloud analysis framework
Jisheng Dang$\dagger$, Delin Deng$\dagger$, Bimei Wang, Jingze Wu, Hui Zhang, Haijiang Li, Jingmei Jiao, Dengyue Pan, Mangang Xie, Jizhao Liu$^{\ast}$
Proceedings of the AAAI Conference on Artificial Intelligence, 40(5), 3506-3514, 2026
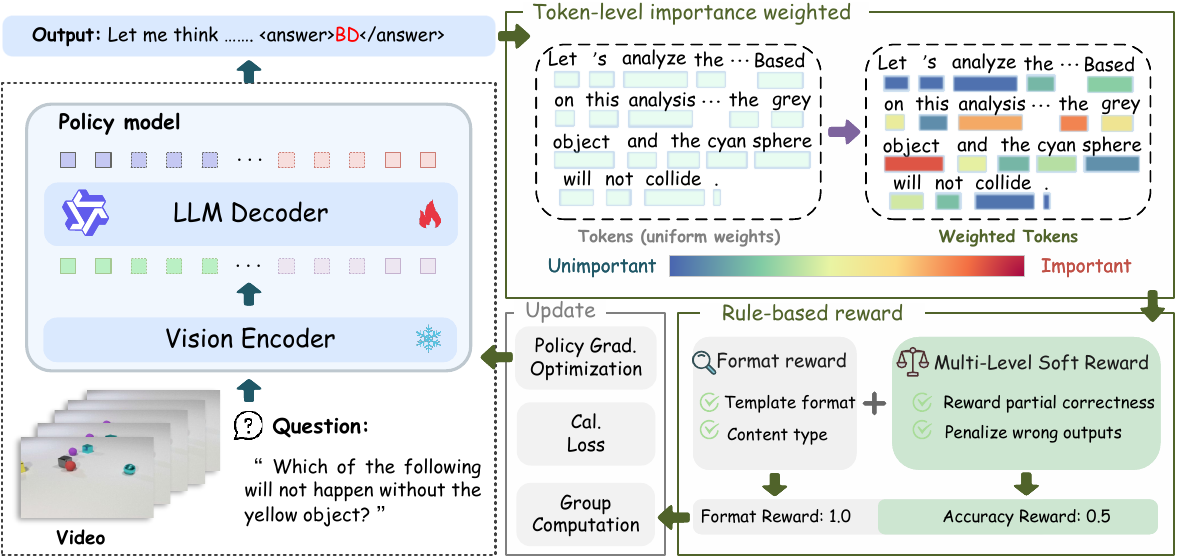
Reinforcing Video Reasoning with Focused Thinking
Jisheng Dang$\dagger$, Jingze Wu$\dagger$ (Student first author), Teng Wang$^{\ast}$, Xuanhui Lin, Nannan Zhu, Hongbo Chen, Wei-Shi Zheng, Meng Wang, Tat-Seng Chua
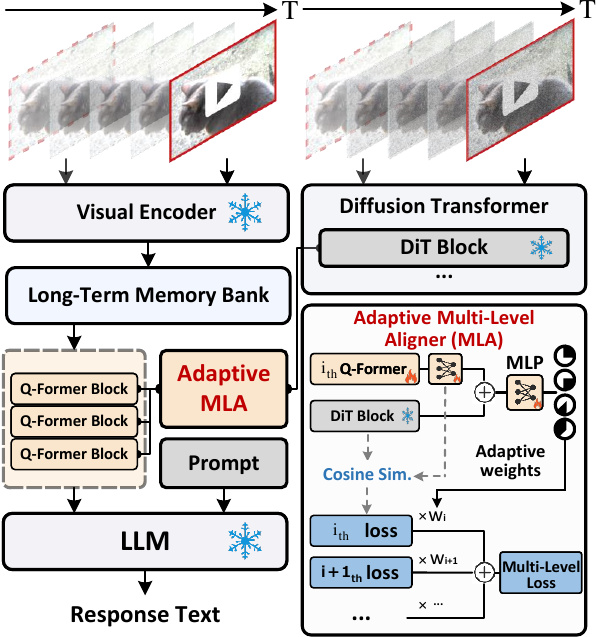
Diff-LMM: Diffusion Teacher-Guided Spatio-Temporal Perception for Video Large Multimodal Models
Jisheng Dang$\dagger$, Ligen Chen$\dagger$, Jingze Wu, Ronghao Lin, Bimei Wang, Yun Wang, Liting Wang, Nannan Zhu, Teng Wang$^{\ast}$
The 34th International Joint Conference on Artificial Intelligence, 873-881, 2025
🎖️ Awards
- “HUAWEI Cup” the 21st China Post-Graduate Mathematical Contest in Modeling - Second Prize (2024)
- The First-Class Postgraduate Scholarship (2023)
- The 22nd National Collegiate Robotics Competition ROBOCON 2023 - Second Prize (2023)
- Science and Technology Star, College of Sciences, Northeastern University (2022)
- The 21st National Collegiate Robotics Competition ROBOCON 2022 - Runner-up (2022)
- The 21st National Collegiate Robotics Competition ROBOCON 2022 - Quadruped Robot - Third Prize (2022)
- The 20th National Collegiate Robotics Competition ROBOCON 2021 - First Prize (2021)
🤖 Competitions
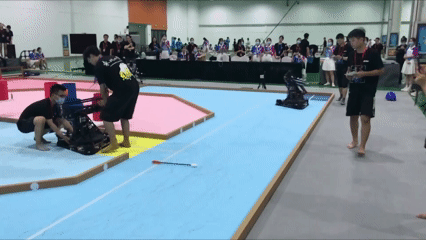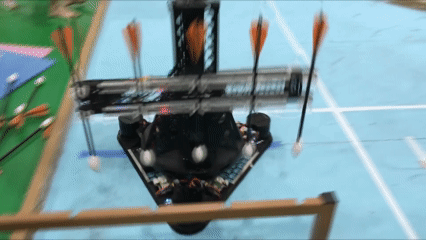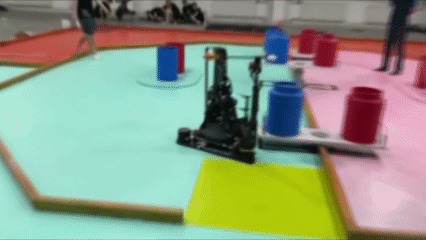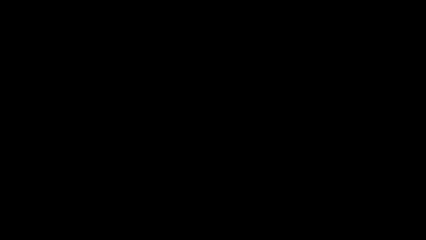
ROBOCON National Robot Competition (2021-2023)
- Implemented a multi-sensor fusion system via an inertial navigation module (IMU \& wheel odometry) while using tightly coupled LiDAR data to correct for cumulative drift.
- Designed and deployed the complete human-robot interaction pipeline, from low-level RF communication module to a high-level Android GUI
Awards: First Prize (2021), Runner-up (2022), Second Prize (2023)
🕴️ Academic Services
- Conference Reviewer
- AAAI, ICME, PRCV
- Journal Reviewer
- IEEE TNNLS